内容简介
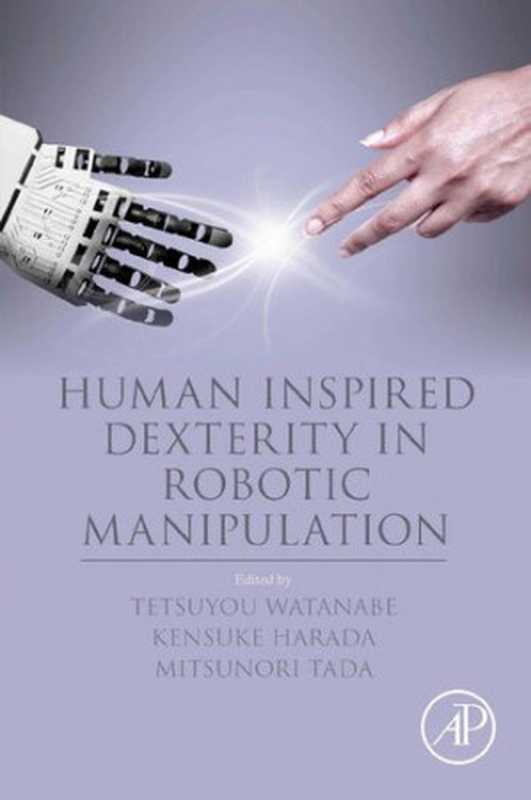
书名:Human Inspired Dexterity in Robotic Manipulation出版社:Academic Press
作者:Tetsuyou Watanabe, Kensuke Harada, Mitsunori Tada
出版年份:2018
电子书格式: pdf
简介:Dive deep into the fascinating world of robotic manipulation with this comprehensive academic text. “Human Inspired Dexterity in Robotic Manipulation” by Watanabe, Harada, and Tada (2018) provides cutting-edge insights into human-inspired approaches to dexterous robotic manipulation. Explore the latest advancements in robotics, focusing on enhancing dexterity, mimicking human capabilities and developing next-generation robotic systems. Discover practical applications and theoretical frameworks in this in-depth analysis for researchers and engineers in robotics and related fields.
ISBN:9780128133859, 01281